USA
 Canada
 Germany
 France
 UK
 Japan
 Korea
 Australia
 Indonesia
 Vietnam
 South Africa
 Rwanda
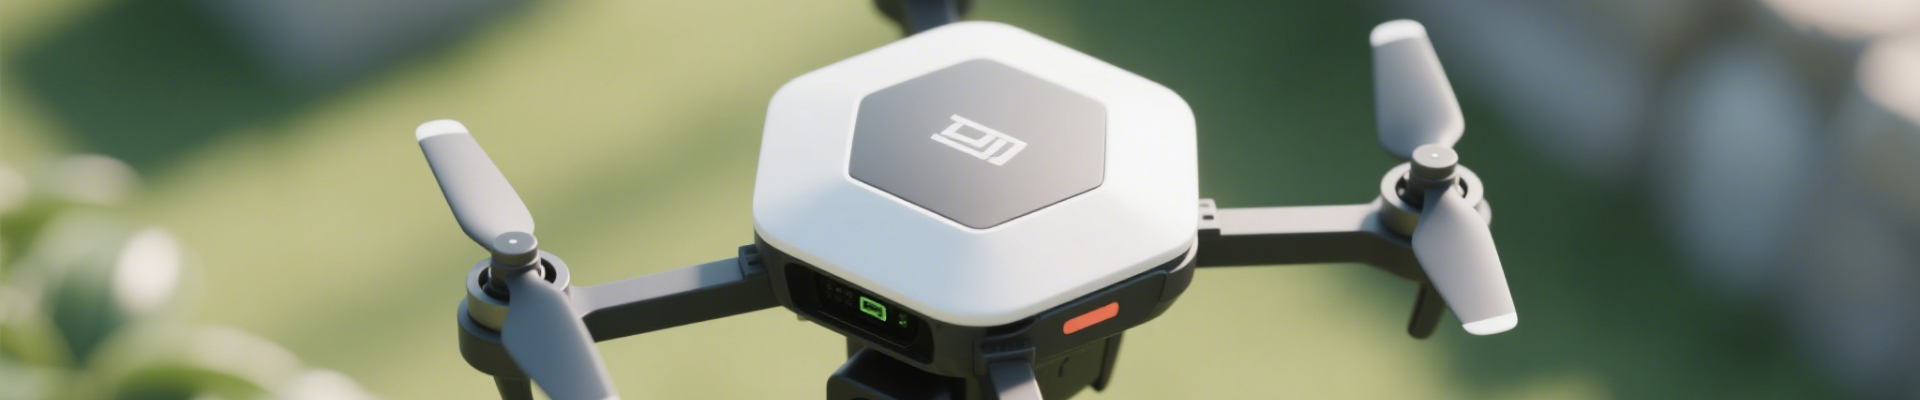
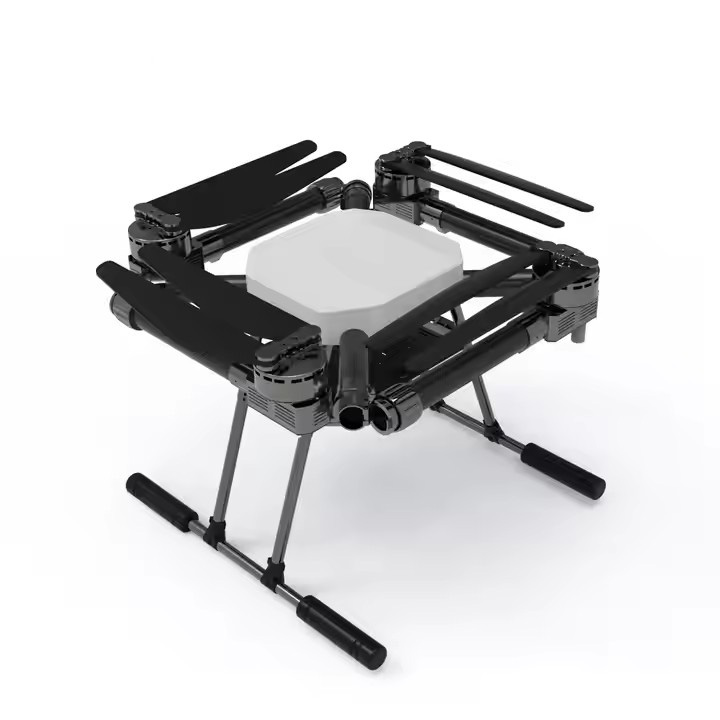
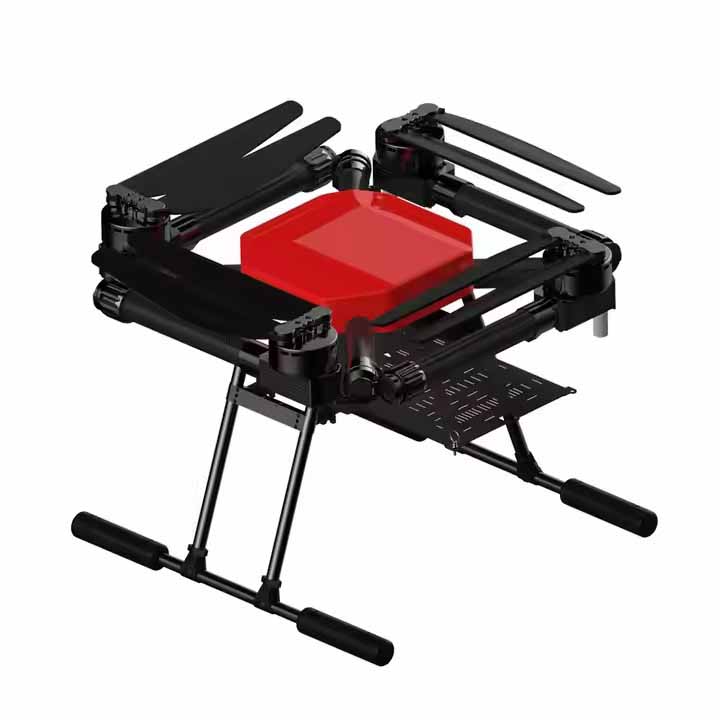
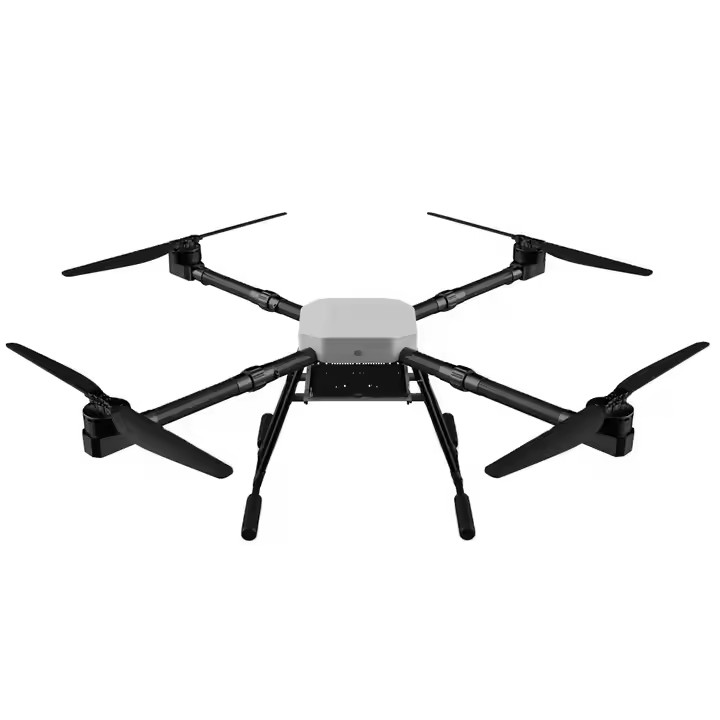
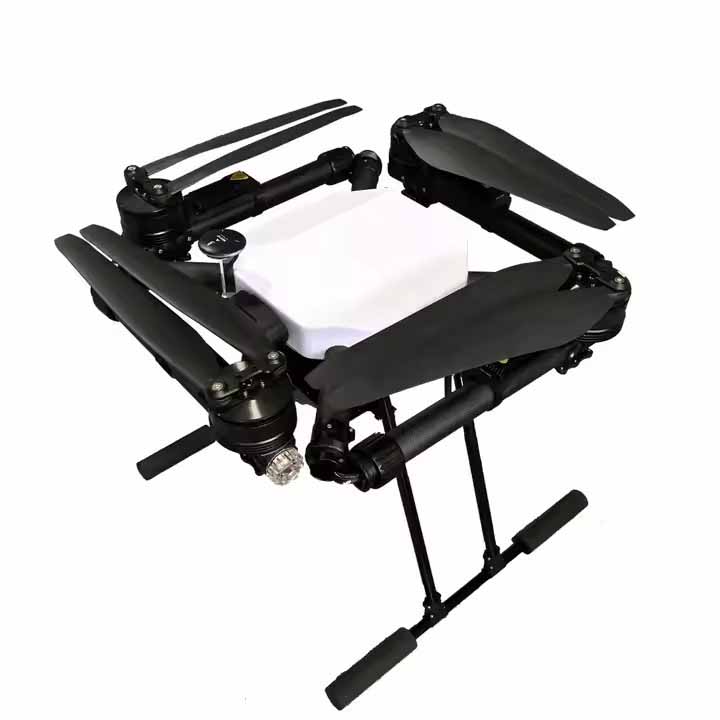
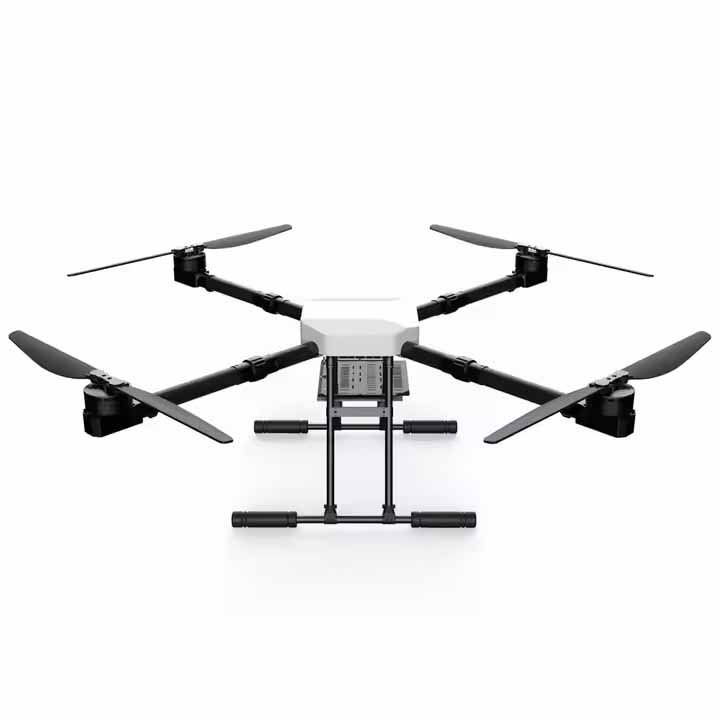
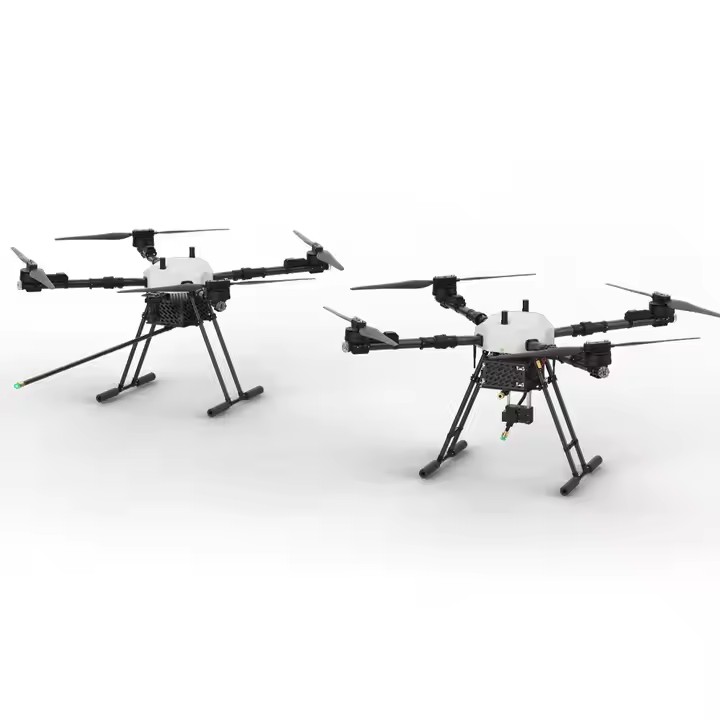
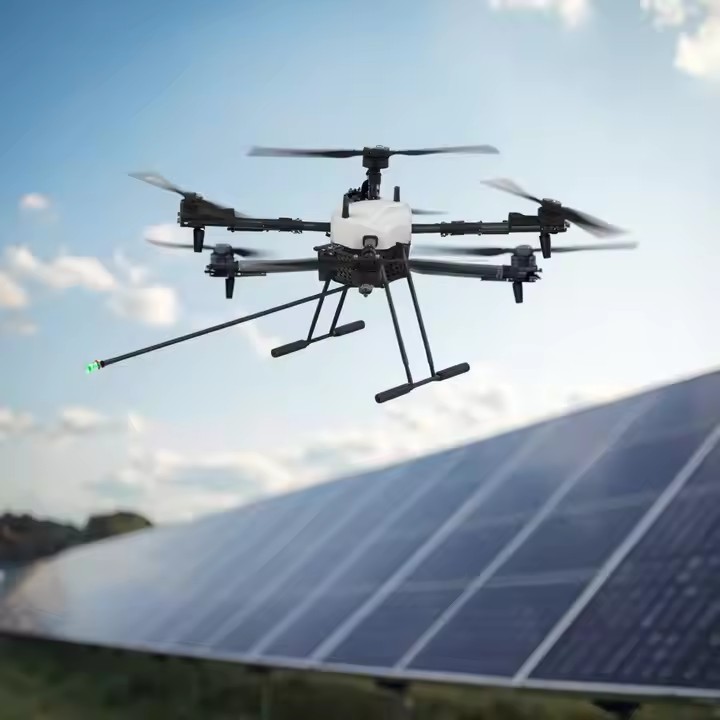
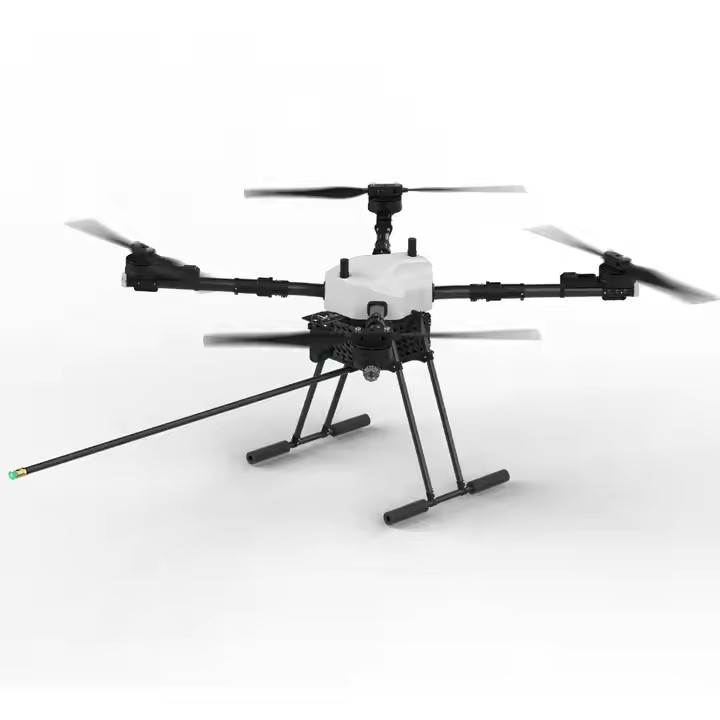
Multi-rotor UAV, is a specialized unmanned rotorcraft with three and more rotor axes. It generates lift and thrust by rotating an electric motor on each axis, which drives the rotor blades. The total pitch of the rotors is fixed, rather than variable as in a typical helicopter. Basic terms related to multi-rotor drones, a must for beginners.
Multi-rotor UAV
UAV: Abbreviation for UnmannedAerialVehicle.
② UAS: Abbreviation for UnmannedAircraftSystem.
③ Wheelbase: Usually measured in millimeters (e.g., 350mm), the size refers to the maximum point-to-point distance between two motors on a UAV. The size may also describe the type of drone (mini, micro, etc.). For example, F450 is a multi-axis UAV with a 450mm wheelbase.
④ Center of Gravity: The center of gravity of the UAV should be located at a point where the gravity of the body is equally distributed both front and back (the location of the center of gravity is very important when designing a UAV).
⑤ Frame: The frame of a UAV is similar to a human skeleton, the frame holds up all the parts and protects important parts such as the flight control.
⑥ Landing gear: In order for a drone to land without easily damaging fragile devices, a landing gear must be used. It uses plastic, metal or rubber materials to cushion the landing.
(7) Propeller protection cover: The propeller protection cover can effectively prevent the propeller from colliding with the external environment, and also protect the personnel from propeller cuts.
Sensor part
① Gyroscope: The gyroscope is used to measure the angular velocity on the X, Y and Z axes, allowing the UAV to fly smoothly.
② Accelerometer: This sensor is designed to measure line acceleration.
③ Barometer: This sensor provides the height of the drone from the ground by measuring air pressure. Barometric pressure varies with altitude, and the drone can determine its own altitude by using the barometer.
GPS: Short for “Global Positioning System”, the GPS sensor allows the drone to be positioned by satellite and sends real-time information to the ground about the drone's location.
System parts
ESC: “Electronic Speed Controller” is used to connect the motor, battery and receiver to regulate the speed of motor rotation.
② Li-po: “lithium polymer battery” is the main power supply equipment for multi-rotor UAV, this kind of battery has high life and high voltage.
③Motor: The motor is the part that drives the propeller in the UAV, and currently the mainstream motor is an external rotor brushless motor.
④ Distribution board: in order to power different parts of the UAV, the battery power must be shared or dispersed among different devices, which requires a distribution board. The distribution board draws a single negative and positive terminal from the drone's battery and provides many connection points throughout the drone in order to provide different voltages to other devices.
⑤ Mapping: It refers to the real-time image wireless transmission system (5.8Ghz mapping and WIFI mapping, etc.), which consists of transmitter, receiver, and display.
The above is the basic terminology related to multi-rotor UAV, hope it is helpful to you. In addition, a UAS consists of a system consisting of a UAV flight platform, associated remote control station, required command and control data links, and any other components specified in the approved type design. If you have any other questions about multi-rotor drones you may want to call us, I am happy to serve you.